What you see
Verify fails for a sketch using Servo. There is no single universal Servo error; preserve the exact first diagnostic from Build Output.
Likely causes
- The include or Servo object declaration differs from the bundled example.
- The selected target or another timer-dependent library conflicts with the sketch.
- A larger project exceeds flash or static SRAM limits even though a small Servo sketch builds.
Diagnostic steps
Open the known Servo example
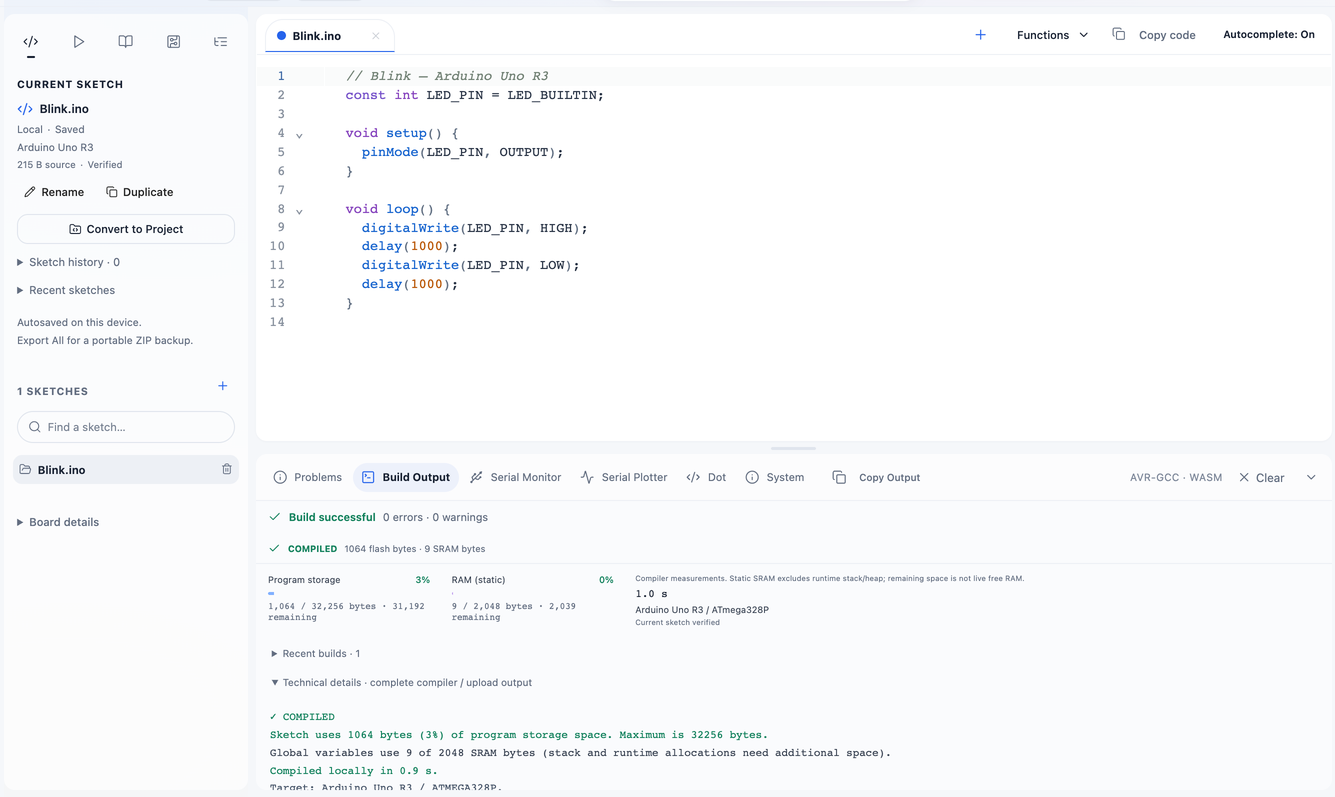
Create a separate Servo Sweep tutorial or library example, select the exact board, and Verify. Compare its real compile status and memory use on the Servo reference page.
Read the earliest diagnostic
A missing Servo.h follows the library-not-found path. An undeclared object follows the identifier guide. A failed build is not evidence that a servo’s wiring or power is wrong.
Add integrations one at a time
Reintroduce your other libraries and source files incrementally. Servo uses timers; PWM availability and timer interactions are board-dependent.
Separate compilation from motor testing
Only after Verify succeeds should you test a positional servo with appropriate power and common ground. Simulation models angle, not all real torque/current behavior.
Board-specific notes
The pinned library uses Timer1 on Uno. Consult the selected board’s library matrix and upstream Servo source before combining timer features. A successful compile is not physical motor validation.
Safe recovery
Return to the minimal working example, preserve the failed project, and document the first error with the selected board/profile.
Evidence and references
Reviewed 2026-10-23 against Circuitera’s actual behavior. An editorial review is separate from a physical board test.
Circuitera implementation evidence
src/libraryExamples.js: Servo sweep; reports/classic-compatibility.json; src/compilerDiagnostics.js